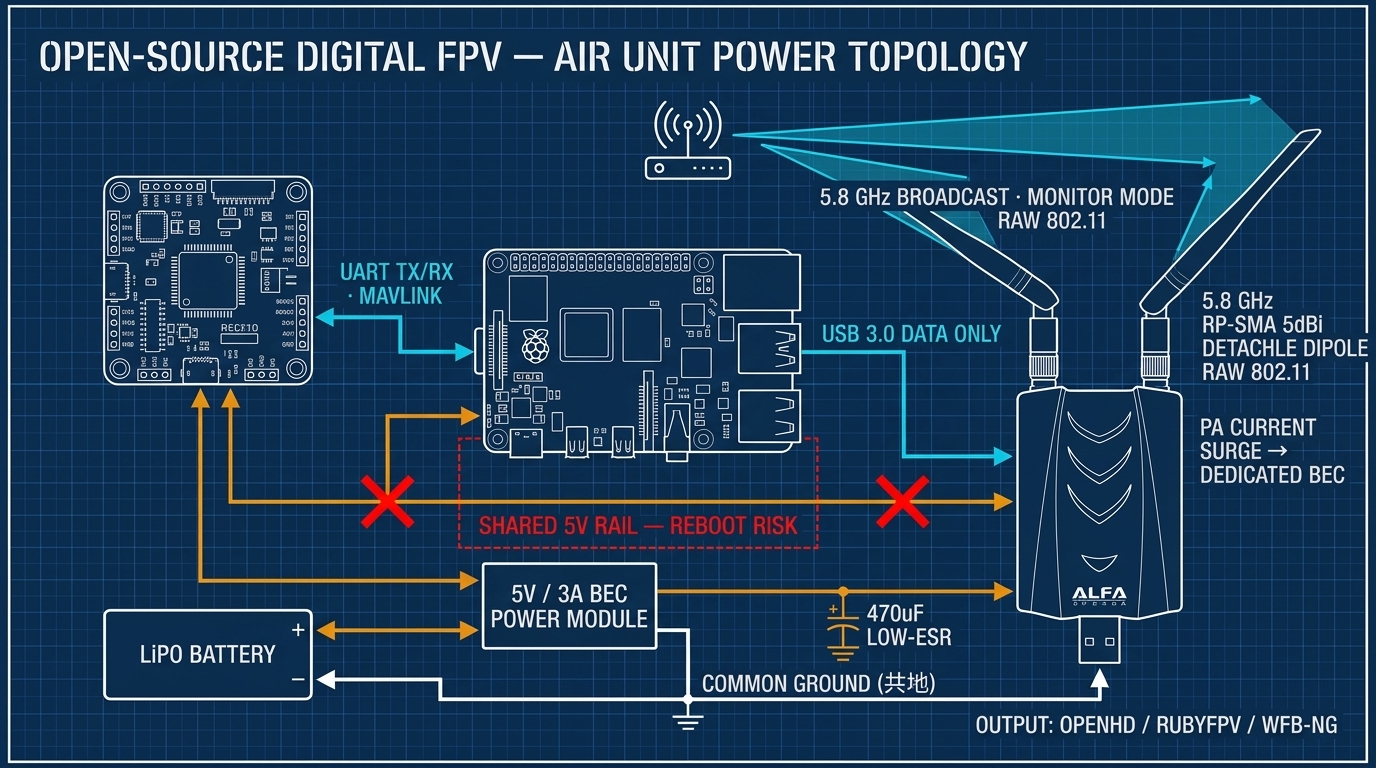
Overview and Technical Background#
Master open-source digital FPV wireless broadcast fundamentals, compare OpenHD, RubyFPV, and WFB-ng stacks, and prevent in-flight brownouts with dedicated BEC wiring for AWUS036ACH.
Key Features and Architectural Highlights#
- Hardware Platform: AWUS036ACH with optimized RF performance.
- Operating System Compatibility: Native support across modern Linux distributions (Kali Linux, Ubuntu, Debian, Raspberry Pi OS).
- Core Advantages: High-gain antennas, reliable RF signal propagation, and hassle-free operation.
Technical Deep Dive and Implementation#
For complete technical specifications, refer to the engineering blueprint above. When configuring high-performance wireless adapters in mission-critical environments (such as robotics, drone FPV links, or penetration testing labs), prioritizing native driver support and dedicated power isolation ensures zero downtime.
Pre-Deployment Checklist#
- Verify hardware detection via
lsusbor system diagnostics. - Ensure firmware packages (
linux-firmware) are up-to-date. - Validate RF spectrum and signal levels before operational deployment.
- Always adhere to local radio frequency regulations and test only within authorized scopes.